Sim-to-Real Reinforcement Learning for Robotics
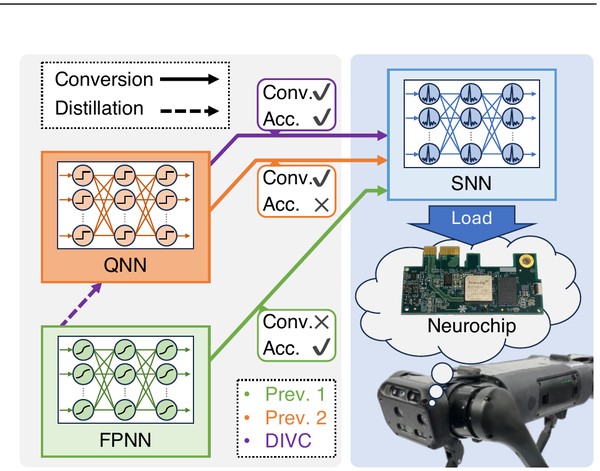
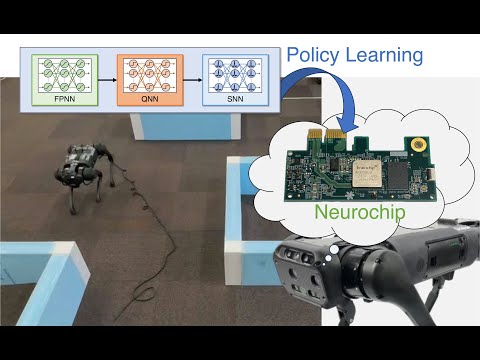
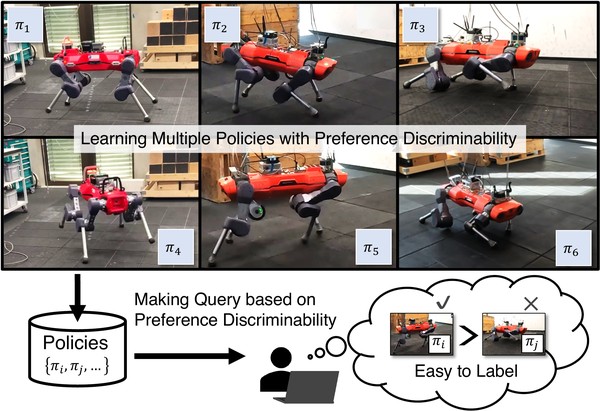
I am a researcher in reinforcement learning (RL), deep learning, and robotics. My research focuses on Sim-to-Real transfer — how robots can learn in simulation and operate in the real world — using methods such as domain randomization, policy distillation, and sample-efficient reinforcement learning. I have worked on real-world robotic tasks including manipulation, legged locomotion, multi-robot systems, and field and industrial robotics.
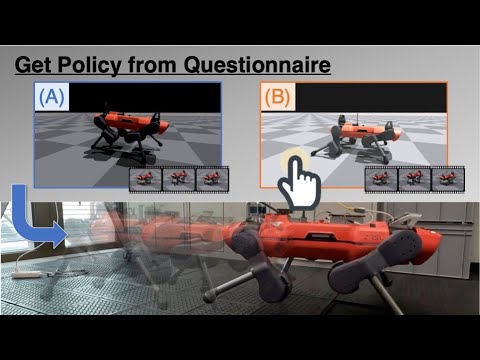
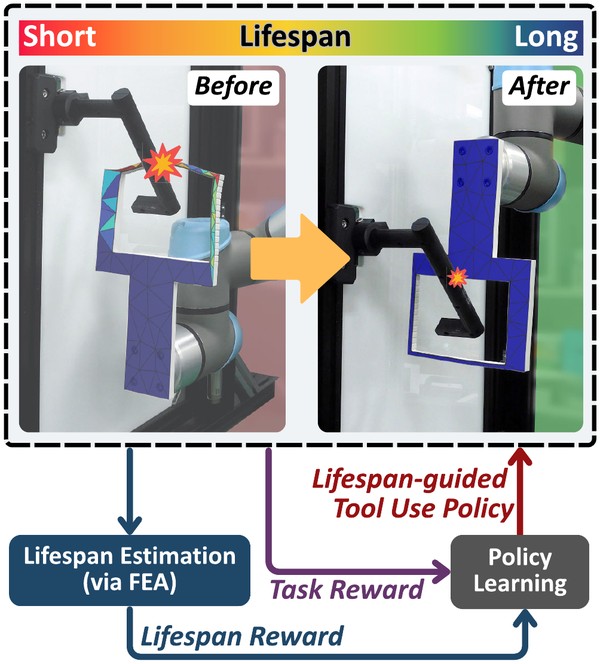
IEEE Access, 2026
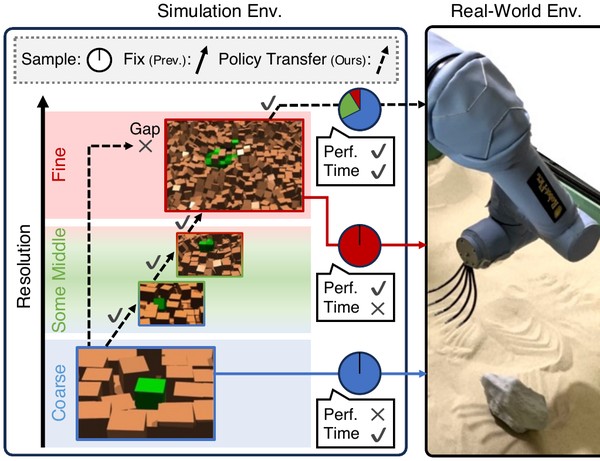
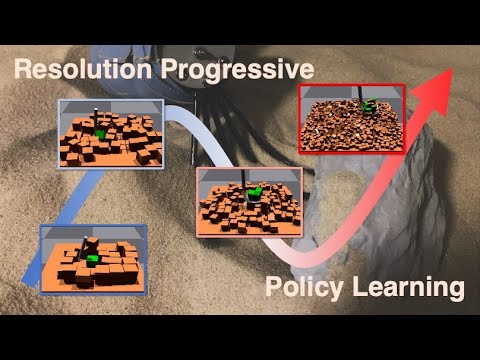
IEEE Transactions on Automation Science and Engineering (T-ASE), 2025
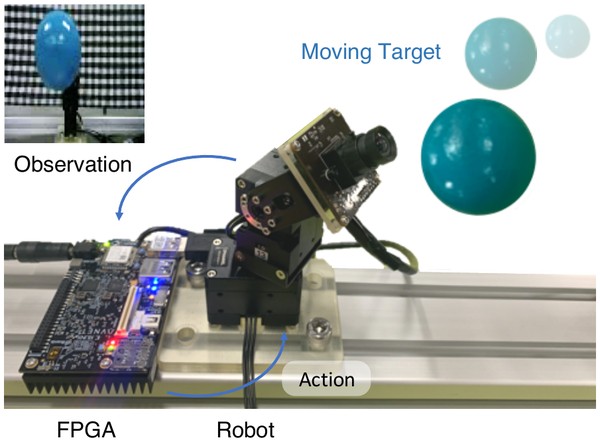
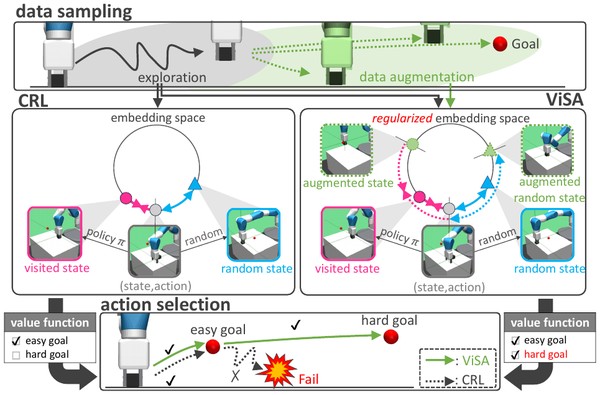
Under review
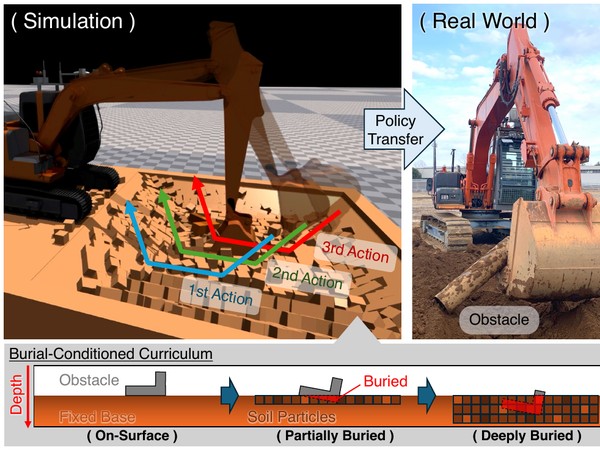
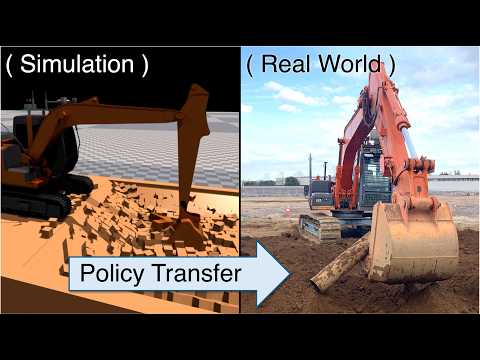
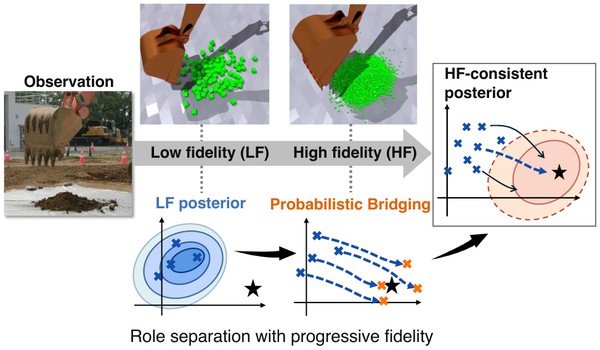
Under review
IEEE International Conference on Robotics and Automation (ICRA, T-ASE option), 2026
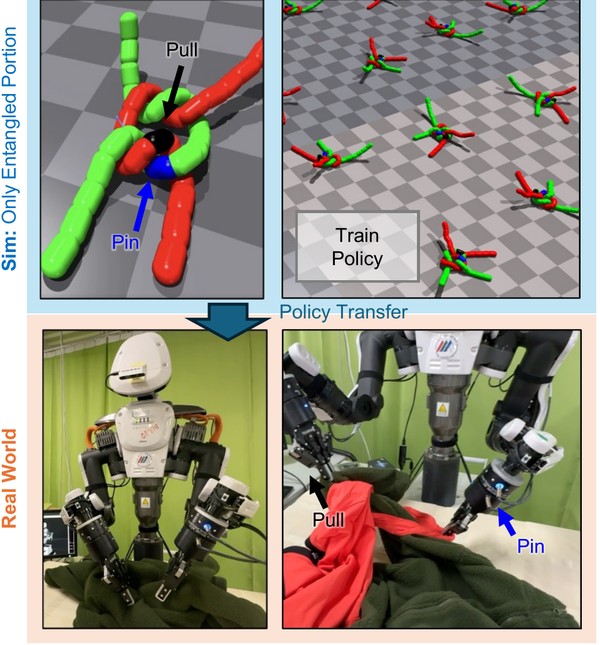
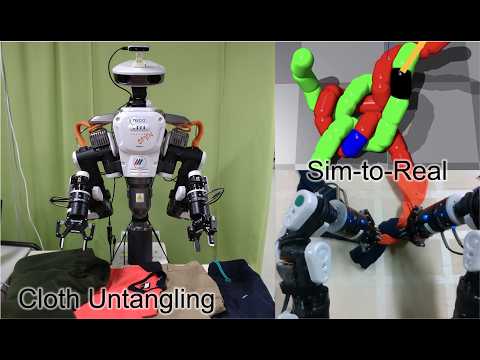
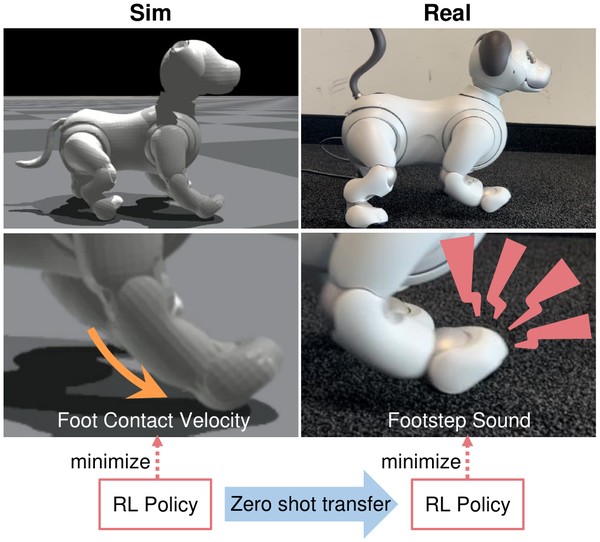
International Conference on Robotics and Automation (ICRA), 2025
International Symposium on Artificial Life and Robotics (AROB), 2025
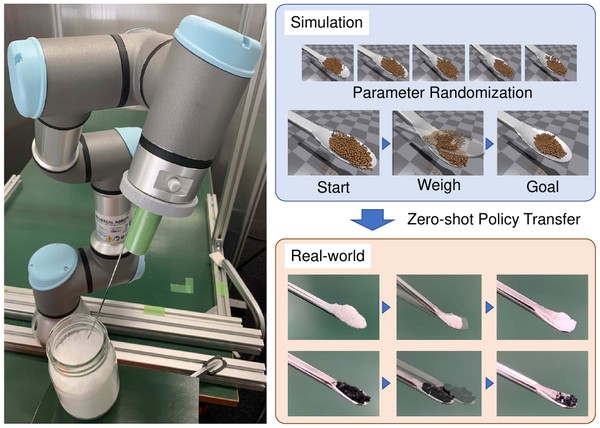
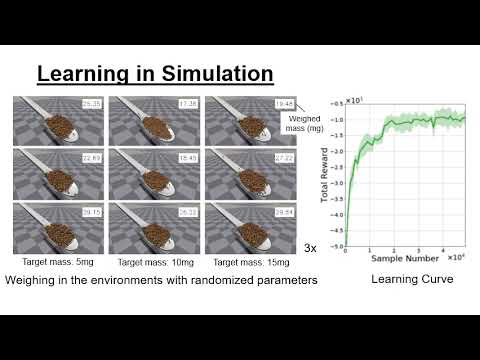
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023
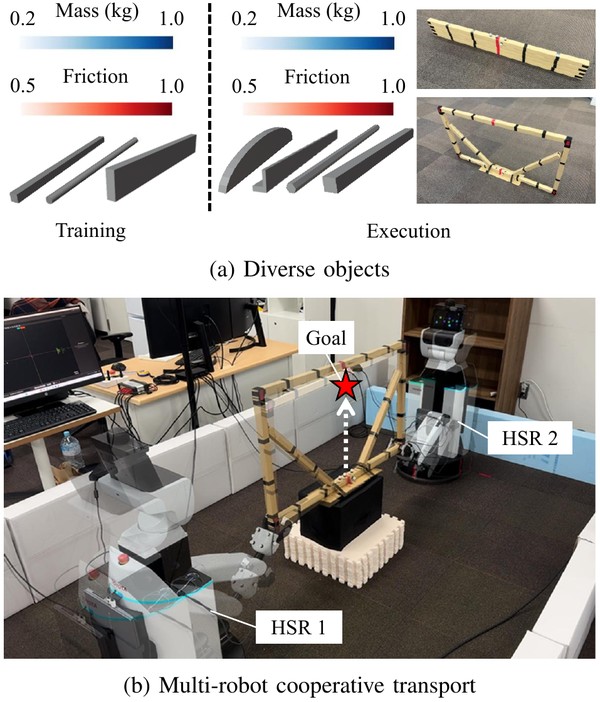
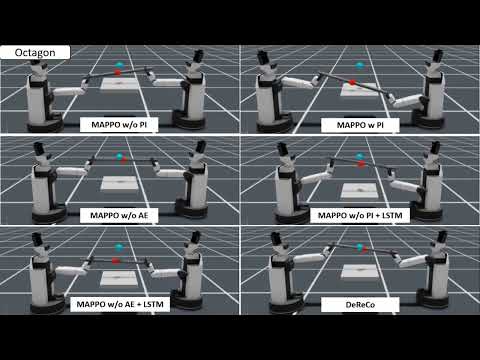
Annual Conference of the Robotics Society of Japan, 2026
Annual Conference of the Robotics Society of Japan, 2024
計測自動制御学会 自律分散システム・シンポジウム, 2026